2025
Semantic Enrichment of CAD-Based Industrial Environments via Scene Graphs for Simulation and Reasoning
Nathan Pascal Walus, Ranulfo Bezerra, Shotaro Kojima, Tsige Tadesse Alemayoh, Satoshi Tadokoro, Kazunori Ohno
IEEE SSRR 2025·Conference
Current research·2025 —
Turning CAD models into structured, queryable world representations that robots and reasoning systems can share.
Supervised student: Nathan Pascal Walus
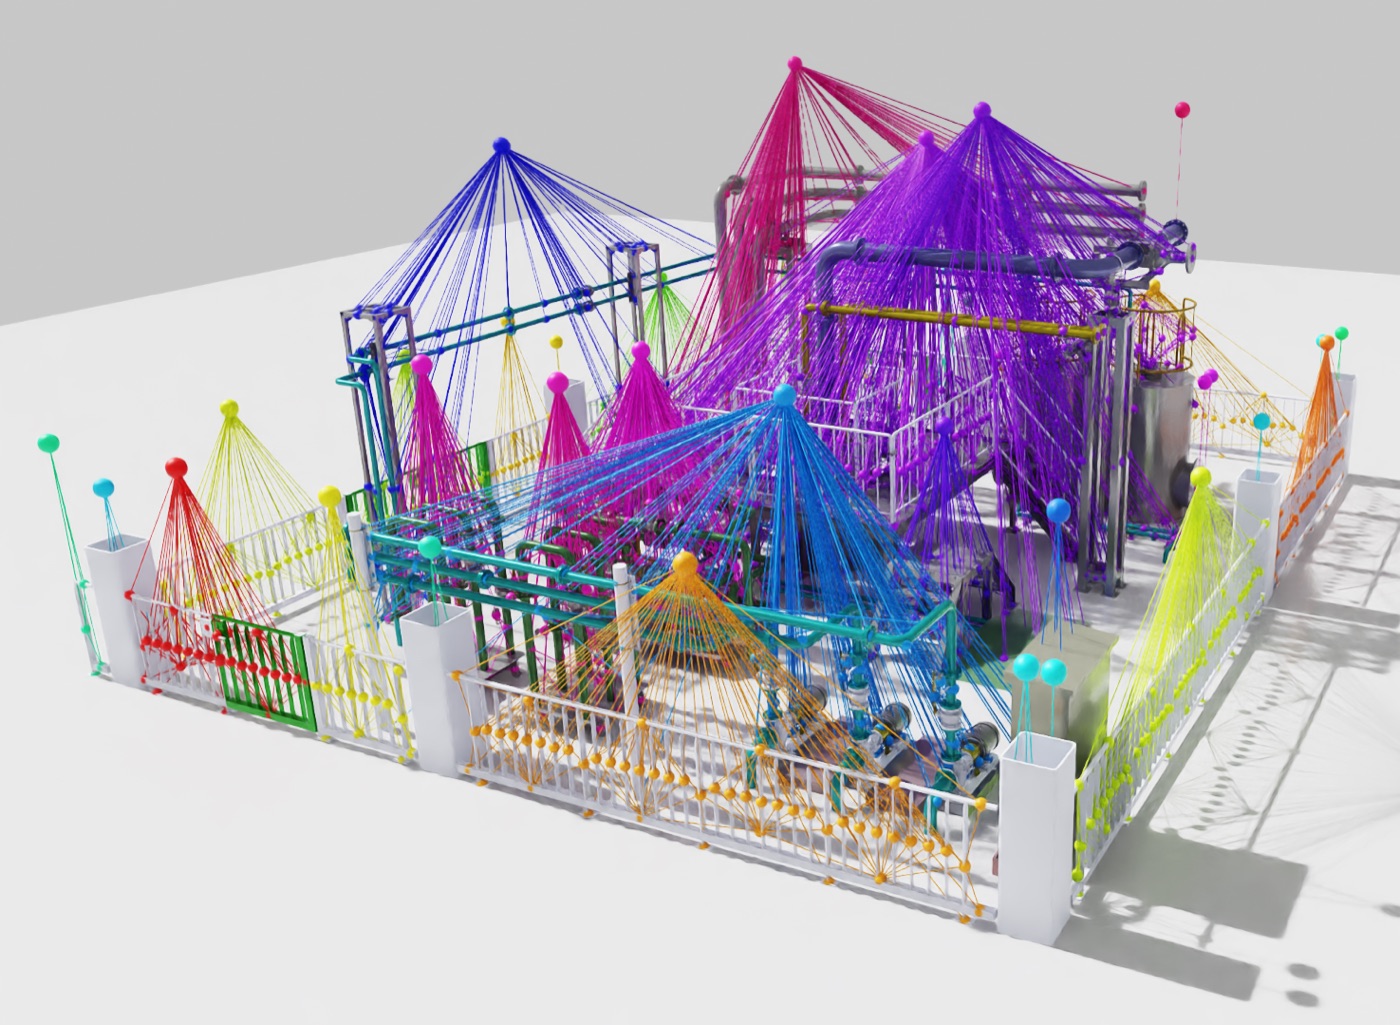
CAD files describe geometry but carry almost no semantic, relational, or functional information — which is exactly what a robot needs in order to reason about a plant. This work builds an offline pipeline that enriches CAD-based industrial environments into 3D scene graphs, using vision-language models to recover object semantics and the spatial and functional relations between elements such as displays, valves, and structures. The result is a shared representation that supports simulation, robot training, and high-level scene reasoning from the same source of truth.
01/Representative publications
1
2025
Nathan Pascal Walus, Ranulfo Bezerra, Shotaro Kojima, Tsige Tadesse Alemayoh, Satoshi Tadokoro, Kazunori Ohno
IEEE SSRR 2025·Conference